

IVRESS
-
Time-accurate parallel explicit-time integration computational mechanics solver.
-
Rigid multibody dynamics
-
Kinematic joints. A penalty formulation is used to model joints
including: spherical, revolute, cylindrical, and prismatic joints. -
Frictional contact using an asperity-based friction model.
-
Rotary and linear actuators.
-
Sensors: position, velocity, acceleration, angle,
angular velocity, and angular acceleration. -
Controllers: PID; Custom
-
-
Finite Element Method
-
Hexahedron (Brick)
-
Quadrilateral (shell)
-
Thick beam
-
Thin beam
-
Truss/spring
-
Torsional spring
-
-
Particle methods
-
SPH (Smoothed Particle Hydrodynamics) for modeling fluid flow.
-
DEM (Discrete Element Method) for modeling frictional and/or
cohesive granular materials including soils and bulk materials. -
MD (Molecular Dynamics).
-
-
Height-field terramechanics for simulation of ground vehicles on soft-soil terrains.
-
RT (Ray Tracing) for photorealistic rendering, radiation modeling, and modeling line-of-sight coating processes including EB-PVD and thermal spray.
-
Scientific visualization for complex large-scale scientific time-dependent datasets.
-
2D/3D graphs
-
Colored surfaces
-
Contour lines
-
Iso-surfaces
-
Surface and volume arrows
-
Streamlines
-
Streak-lines
-
Vortex cores
-
Separation and attachment
lines and surfaces
-
-
IK (Inverse Kinematics) for calculating robot limb link angles necessary for a desired end effector position & orientation.
-
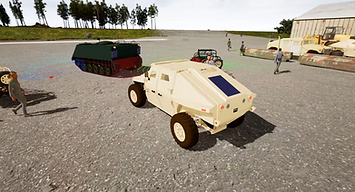
Unreal Game Engine integration for real-time photorealistic visualization using the IVRESS-Unreal plugin.
-
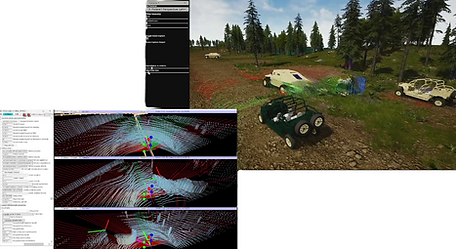
Exteroceptive sensors models (modeled using the IVRESS-Unreal plugin)
-
Visible light and IR cameras
-
Lidar
-
Radar
-
Ultrasound sensor
-
-
AI (Artificial Intelligence) for image segmentation and visual object recognition.
-
AScience autonomy stack for on- and off-road ground vehicles navigation with local and global path planners and integration with AI image segmentation and object recognition.
- Scripting.
- JAVA script
- Python script
-
Pre-processor and post-processor
-
Object-oriented architecture with a hierarchical model tree editor.
-
Template/spreadsheet pre-processor
-
-
Co-simulation with other codes such as Matlab, Simulink and ROS2.






IVRESS Applications
-
Off-road ground vehicles: Terramechanics (vehicle mobility and interaction with soft-soils)
-
Agricultural: tractors; plows; planters; tillers; harvesters.
-
Military: tracked vehicles; wheeled vehicles; tanker trucks.
-
Autonomous ground vehicles: high-fidelity vehicle, sensor, and environment models integrated with the vehicles' autonomy stack.
-
Construction: structures; cranes; elevators/hoists; earth moving equipment.
-
Aerospace: landing gears; flaps; rudder; airplanes.
-
Mechanical sub-systems: gear drives; cams; belt-drives; chain-drives; toroidal CVTs.
-
Transportation systems: Elevators; cable cars.
-
Manufacturing: metal removal; additive manufacturing; extrusion; sheet metal forming; coating.
-
Robotics: robot arms; autonomous vehicles; legged robots (including quadropedal and bipedal).
-
Biodynamic systems: humans; animals; insects.
-
Mining: earth moving equipment; bulk material conveyors; silos.
-
Energy: mechanical power transmission systems (gear and chain drives ); turbines; energy harvesting.
-
Marine: ships; submarines; tankers; propellers.
Features


Parallel processing
Scale your productivity and reduce the simulation time by running the simulation on multiple processors. IVRESS can run different bodies simulation on different computer nodes, enabling the user to allocate more computing resources and get the job done!
Co-simulation capability
Integrate IVRESS in your current ecosystem. IVRESS can integrate with other software to co-simulate MBD models with third-party software.


